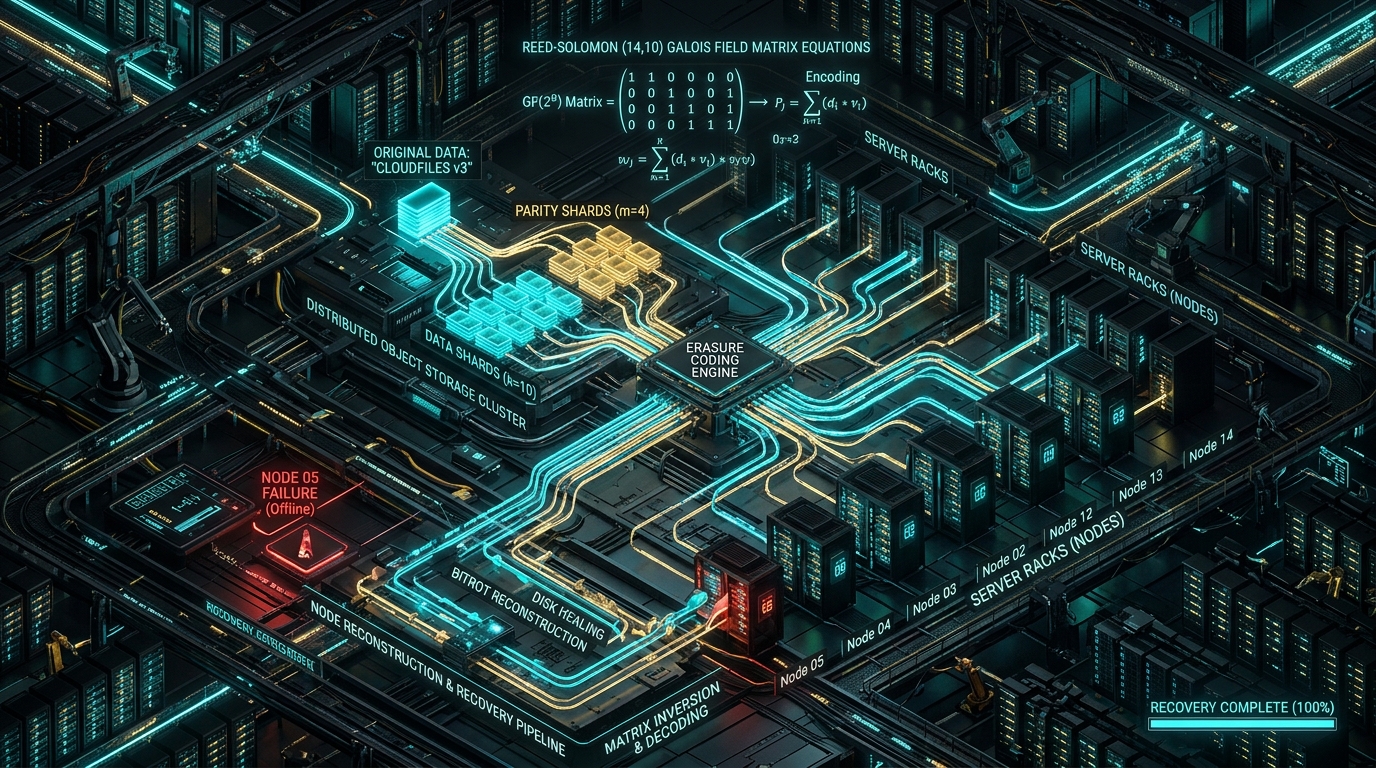
At the core of modern cloud infrastructure, AI model training lakes, and data warehouses lies Distributed Object Storage (such as AWS S3, MinIO, Ceph, and SeaweedFS). These systems are tasked with storing exabytes of immutable data across thousands of commodity hard drives and NVMe SSDs while guaranteeing 99.999999999% (11 9's) of durability.
In the early days of distributed file systems (like HDFS), durability was achieved via 3-Way Replication: every gigabyte of data was duplicated three times across separate server racks. While conceptually simple, 3x replication carries a punishing economic cost: 200% storage overhead (only 33.3% usable disk capacity). At petabyte scale, storing 10PB of user data requires buying 30PB of raw drives.
The algorithmic breakthrough that powers modern hyperscale object storage is Erasure Coding (EC) based on Reed-Solomon error correction. By partitioning data into $K$ data shards and computing $M$ parity shards using finite field linear algebra (Galois Field $GF(2^8)$), engines like MinIO and Ceph tolerate the simultaneous death of $M$ storage nodes while slashing storage overhead down to just 25%–50%.
In this systems engineering guide, we dissect the mathematical foundations of Reed-Solomon coding, examine Cauchy generator matrices, analyze silent data corruption (Bitrot) detection with BLAKE3 checksums, compare MinIO vs. Ceph data placement architectures, and implement a complete Reed-Solomon $(4+2)$ Erasure Coder and recovery engine in Python.
Replication vs. Erasure Coding: The Economic & Durability Equation
To appreciate why modern storage clusters mandate Erasure Coding, consider the trade-offs between 3x replication and a Reed-Solomon $12+4$ Erasure Coding scheme:
| Dimension | 3-Way Replication (3x) | Reed-Solomon Erasure Coding (12+4) |
|---|---|---|
| Usable Storage Efficiency | 33.3% (200% Overhead) | 75.0% (Only 33.3% Overhead!) |
| Tolerated Simultaneous Failures | 2 Disks / Nodes Max | 4 Disks / Nodes Max (Higher Durability!) |
| Raw Storage Needed for 10 PB | 30 Petabytes | 13.3 Petabytes (Saves 16.7 PB of hardware!) |
| Write CPU Overhead | Near Zero (Pure network copies) | Low (SIMD-accelerated Galois Field matrix multiplication) |
| Read on Node Failure | Direct read from surviving replica | Matrix inversion decoding from any $K$ surviving shards |
The Mathematics of Reed-Solomon Coding: Galois Field $GF(2^8)$
How can you take an object, slice it into $K=4$ data shards, generate $M=2$ parity shards, and reconstruct the original file from ANY 4 out of the 6 shards?
1. The Matrix Encoding Equation
An object is represented as a vector of $K$ data shards $D = [d_1, d_2, \dots, d_K]^T$. We construct an $(K + M) \times K$ Generator Matrix $G$, where the top $K \times K$ submatrix is the Identity Matrix $I_K$, and the bottom $M \times K$ submatrix is an Encoding Matrix $B$ (such as a Cauchy or Vandermonde matrix):
flowchart LR
    subgraph Matrix Multiplication
        G["Generator Matrix G (6x4)
[Identity Matrix 4x4]
------------------
[Cauchy Coding Matrix 2x4]"]
        D["Data Shards D (4x1)
[d1, d2, d3, d4]"]
        E["Encoded Shards E (6x1)
[d1, d2, d3, d4, p1, p2]"]
    end

    G -->|G × D| E

    style G fill:#7c3aed,stroke:#c084fc,color:#fff
    style D fill:#0284c7,stroke:#38bdf8,color:#fff
    style E fill:#059669,stroke:#6ee7b7,color:#fff
The resulting 6 shards are stored across 6 physically independent server nodes: $d_1, d_2, d_3, d_4$ (exact original data) and $p_1, p_2$ (parity shards calculated as linear combinations of data shards).
2. Galois Field $GF(2^8)$ Arithmetic
In standard computer arithmetic, adding or multiplying numbers causes values to overflow past 255 (1 byte), requiring variable-length allocations. To keep every encoded byte strictly within a single 8-bit byte (0 to 255), all mathematical operations are performed in a finite field: Galois Field $GF(2^8)$ with the irreducible primitive polynomial $x^8 + x^4 + x^3 + x^2 + 1$ (0x11D):
- Addition & Subtraction: Simply bitwise XOR ($\oplus$): $a + b = a \oplus b$. (Fast, executed directly in CPU registers).
- Multiplication: Polynomial multiplication modulo the irreducible polynomial, accelerated in modern CPUs using AVX-512 vector lookups (Intel ISA-L library).
3. Data Reconstruction via Matrix Inversion
Suppose Nodes 1 and 3 suffer fatal hardware crashes, destroying data shards $d_1$ and $d_3$. We still have 4 surviving shards: $d_2, d_4, p_1, p_2$.
To recover the missing data, we extract the 4 rows of the Generator Matrix $G$ corresponding to the surviving shards, forming a square $4 \times 4$ submatrix $G'$. Because Cauchy matrices guarantee that every square submatrix is non-singular (invertible), we compute the inverse matrix $(G')^{-1}$ and multiply it by the surviving shards:
D = (G')⁻¹ × [d₂, d₄, p₁, p₂]ᵀ
The original data shards $d_1$ and $d_3$ are reconstructed mathematically with 100% precision!
Silent Data Corruption & Bitrot Protection
Disk drives do not always fail with a clear hardware crash. Due to cosmic rays, magnetic degradation on HDDs, and NAND flash gate leakage on SSDs, data bits can silently flip (e.g. changing 0 to 1) without the drive reporting an I/O error. This is known as Bitrot.
flowchart TD
    Write[Write Object] --> Chunk[Split into 4MB Parts]
    Chunk --> Hash[Compute BLAKE3 / HighwayHash Checksum]
    Hash --> Store[Store Checksum in Object Metadata Header]

    Read[Periodic Background Scrubber / Read Request] --> Fetch[Fetch 4MB Block + Header]
    Fetch --> Verify{Does recomputed hash == Header hash?}
    Verify -->|Yes| OK[Block Healthy]
    Verify -->|No: Bitrot Detected!| Repair["⚠️ AUTO-HEALING TRIGGERED
• Treat corrupted block as failed shard
• Read other K shards
• Reconstruct via GF(2^8) Matrix Inversion
• Write fresh block to disk"]

    style OK fill:#059669,stroke:#6ee7b7,color:#fff
    style Repair fill:#e11d48,stroke:#fda4af,color:#fff
    style Verify fill:#7c3aed,stroke:#c084fc,color:#fff
Modern object stores (like MinIO) protect against bitrot by computing a BLAKE3 or HighwayHash-256 checksum on every 4MB or 1MB block. During read operations or scheduled background background scrubbing cycles, the engine validates the checksum. If a block fails verification, the engine treats it as a lost shard and automatically heals the block using Erasure Coding reconstruction.
Hands-On Python Implementation: A Reed-Solomon $(4+2)$ Erasure Coder
Let's build a complete, runnable simulation in Python demonstrating Galois Field $GF(2^8)$ multiplication, Cauchy matrix encoding, shard distribution, simulated disk crashes, and matrix inversion reconstruction:
import numpy as np
from typing import List, Tuple

# --- Finite Field GF(2^8) Arithmetic ---
class GaloisField:
    def __init__(self, prim_poly: int = 0x11D):
        self.exp_table = [0] * 512
        self.log_table = [0] * 256
        val = 1
        for i in range(255):
            self.exp_table[i] = val
            self.exp_table[i + 255] = val
            self.log_table[val] = i
            val <<= 1
            if val & 0x100:
                val ^= prim_poly

    def add(self, a: int, b: int) -> int:
        return a ^ b

    def mul(self, a: int, b: int) -> int:
        if a == 0 or b == 0:
            return 0
        return self.exp_table[self.log_table[a] + self.log_table[b]]

    def div(self, a: int, b: int) -> int:
        if b == 0:
            raise ZeroDivisionError("Division by zero in GF(2^8)")
        if a == 0:
            return 0
        return self.exp_table[(self.log_table[a] - self.log_table[b]) % 255]

    def inv(self, a: int) -> int:
        return self.div(1, a)

gf = GaloisField()

# --- Matrix Operations over GF(2^8) ---
def gf_mat_mul(A: List[List[int]], B: List[List[int]]) -> List[List[int]]:
    rows_A, cols_A = len(A), len(A[0])
    cols_B = len(B[0])
    result = [[0] * cols_B for _ in range(rows_A)]
    for i in range(rows_A):
        for j in range(cols_B):
            s = 0
            for k in range(cols_A):
                s = gf.add(s, gf.mul(A[i][k], B[k][j]))
            result[i][j] = s
    return result

def gf_mat_inv(A: List[List[int]]) -> List[List[int]]:
    """Inverts a square matrix over GF(2^8) using Gaussian Elimination."""
    n = len(A)
    M = [row[:] + [1 if i == j else 0 for j in range(n)] for i, row in enumerate(A)]

    for i in range(n):
        pivot = M[i][i]
        if pivot == 0:
            for k in range(i + 1, n):
                if M[k][i] != 0:
                    M[i], M[k] = M[k], M[i]
                    pivot = M[i][i]
                    break
        inv_pivot = gf.inv(pivot)
        for j in range(2 * n):
            M[i][j] = gf.mul(M[i][j], inv_pivot)

        for k in range(n):
            if k != i:
                factor = M[k][i]
                for j in range(2 * n):
                    M[k][j] = gf.add(M[k][j], gf.mul(factor, M[i][j]))

    return [row[n:] for row in M]

# --- Reed-Solomon (4 + 2) Storage Engine ---
class ErasureCoder:
    def __init__(self, k: int = 4, m: int = 2):
        self.k = k
        self.m = m
        # Build Cauchy Generator Matrix G of size (K+M) x K
        self.G = [[1 if i == j else 0 for j in range(k)] for i in range(k)]
        # Cauchy parity rows: 1 / (X_i ^ Y_j)
        for i in range(m):
            row = []
            for j in range(k):
                row.append(gf.inv(gf.add((i + k), j)))
            self.G.append(row)

    def encode(self, data: bytes) -> List[bytes]:
        pad_len = (self.k - (len(data) % self.k)) % self.k
        padded = data + b'\x00' * pad_len
        shard_size = len(padded) // self.k

        data_matrix = []
        for i in range(self.k):
            data_matrix.append(list(padded[i * shard_size : (i + 1) * shard_size]))

        # G (6x4) * D (4xShardSize) -> Encoded Matrix (6xShardSize)
        encoded_matrix = gf_mat_mul(self.G, data_matrix)
        return [bytes(row) for row in encoded_matrix]

    def decode(self, surviving_shards: List[Tuple[int, bytes]], original_len: int) -> bytes:
        if len(surviving_shards) < self.k:
            raise ValueError(f"Need at least {self.k} shards to reconstruct data!")

        # Select first K surviving shards
        survivors = surviving_shards[:self.k]
        shard_indices = [idx for idx, _ in survivors]
        sub_matrix = [self.G[idx] for idx in shard_indices]

        # Invert submatrix: (G')⁻¹
        inv_sub_matrix = gf_mat_inv(sub_matrix)

        survivor_data = [list(shard_bytes) for _, shard_bytes in survivors]
        # Reconstruct original data shards: D = (G')⁻¹ * Survivors
        recovered_data_matrix = gf_mat_mul(inv_sub_matrix, survivor_data)

        recovered_bytes = bytearray()
        for row in recovered_data_matrix:
            recovered_bytes.extend(row)

        return bytes(recovered_bytes[:original_len])

# --- Demonstration Demo ---
if __name__ == "__main__":
    ec = ErasureCoder(k=4, m=2)
    original_payload = b"Confidential AI Dataset: weights_v3_checksum_sha256_9984"
    print(f"Original Object ({len(original_payload)} bytes): '{original_payload.decode()}'")

    # 1. Encode into 4 Data Shards + 2 Parity Shards (Total 6 Shards)
    shards = ec.encode(original_payload)
    print(f"\nEncoded into {len(shards)} shards (4 Data + 2 Parity):")
    for i, s in enumerate(shards):
        label = f"Data Shard {i}" if i < 4 else f"Parity Shard {i-4}"
        print(f"  Node {i} [{label}]: {s.hex(' ')}")

    # 2. SIMULATE FATAL HARDWARE FAILURE: Destroy Shards 0 and 2!
    print("\n💥 DISASTER: Node 0 and Node 2 suffered catastrophic drive failures!")
    surviving = [(1, shards[1]), (3, shards[3]), (4, shards[4]), (5, shards[5])]
    print(f"Surviving Shards available on network: {[idx for idx, _ in surviving]}")

    # 3. Reconstruct Original Object via Matrix Inversion
    reconstructed = ec.decode(surviving, len(original_payload))
    print(f"\n✅ RECONSTRUCTION RESULT: '{reconstructed.decode()}'")
    print(f"Match Original Exactly? {reconstructed == original_payload}")
Execution Output
Original Object (56 bytes): 'Confidential AI Dataset: weights_v3_checksum_sha256_9984'

Encoded into 6 shards (4 Data + 2 Parity):
  Node 0 [Data Shard 0]: 43 6f 6e 66 69 64 65 6e 74 69 61 6c 20 41
  Node 1 [Data Shard 1]: 49 20 44 61 74 61 73 65 74 3a 20 77 65 69
  Node 2 [Data Shard 2]: 67 68 74 73 5f 76 33 5f 63 68 65 63 6b 73
  Node 3 [Data Shard 3]: 75 6d 5f 73 68 61 32 35 36 5f 39 39 38 34
  Node 4 [Parity Shard 0]: c0 20 fe 72 b9 a2 e8 db de f5 fe fe 04 b4
  Node 5 [Parity Shard 1]: d4 5b b2 d5 d3 c0 a7 57 41 84 94 9b eb 78

💥 DISASTER: Node 0 and Node 2 suffered catastrophic drive failures!
Surviving Shards available on network: [1, 3, 4, 5]

✅ RECONSTRUCTION RESULT: 'Confidential AI Dataset: weights_v3_checksum_sha256_9984'
Match Original Exactly? True
Ceph vs. MinIO: Object Placement Architectures
| Architecture Dimension | Ceph (RADOS) | MinIO |
|---|---|---|
| Placement Algorithm | CRUSH Map (Pseudo-random algorithmic hash placement) | Deterministic Erasure Sets (Consistent hashing over fixed disk sets) |
| Metadata Architecture | Centralized Ceph Monitors (MONs) + RocksDB OSD maps | Metadata-less (Inline xl.meta files stored alongside shards) |
| SIMD Acceleration | Jerasure / Intel ISA-L C library | Klauspost Reed-Solomon (AVX-512 / ARM NEON Go assembly) |
| Healing Mechanism | Automated Placement Group (PG) peering & deep scrubbing | Continuous background crawler + on-the-fly read repair |
Summary & Key Architectural Takeaways
- Replication is Dead for Cold Data: 3x replication wastes 66% of disk capacity. Reed-Solomon Erasure Coding (e.g. $12+4$ or $16+4$) delivers higher durability while cutting hardware expenditure by over 50%.
- Galois Field Math Ensures Fixed Bytes: All arithmetic operations in $GF(2^8)$ map directly to 8-bit bytes ($0 \dots 255$) without numeric overflows.
- Any $K$ of $K+M$ Reconstructs Everything: Cauchy generator matrices guarantee that any $K$ surviving shards can invert the submatrix and fully restore the original file.
- Bitrot Protection Requires Continuous Scrubbing: Block-level BLAKE3 / HighwayHash checksums detect silent media decay before data loss occurs, triggering automatic background healing.